The Encoder Is Right. The Optics Have Moved.
A joint encoder measures the angle between its own mounting parts. Trace the remaining mechanical path to find hidden flex, changing optical alignment and shared thermal causes before spending on finer feedback.
Download the article (PDF)PDF · 964 KB
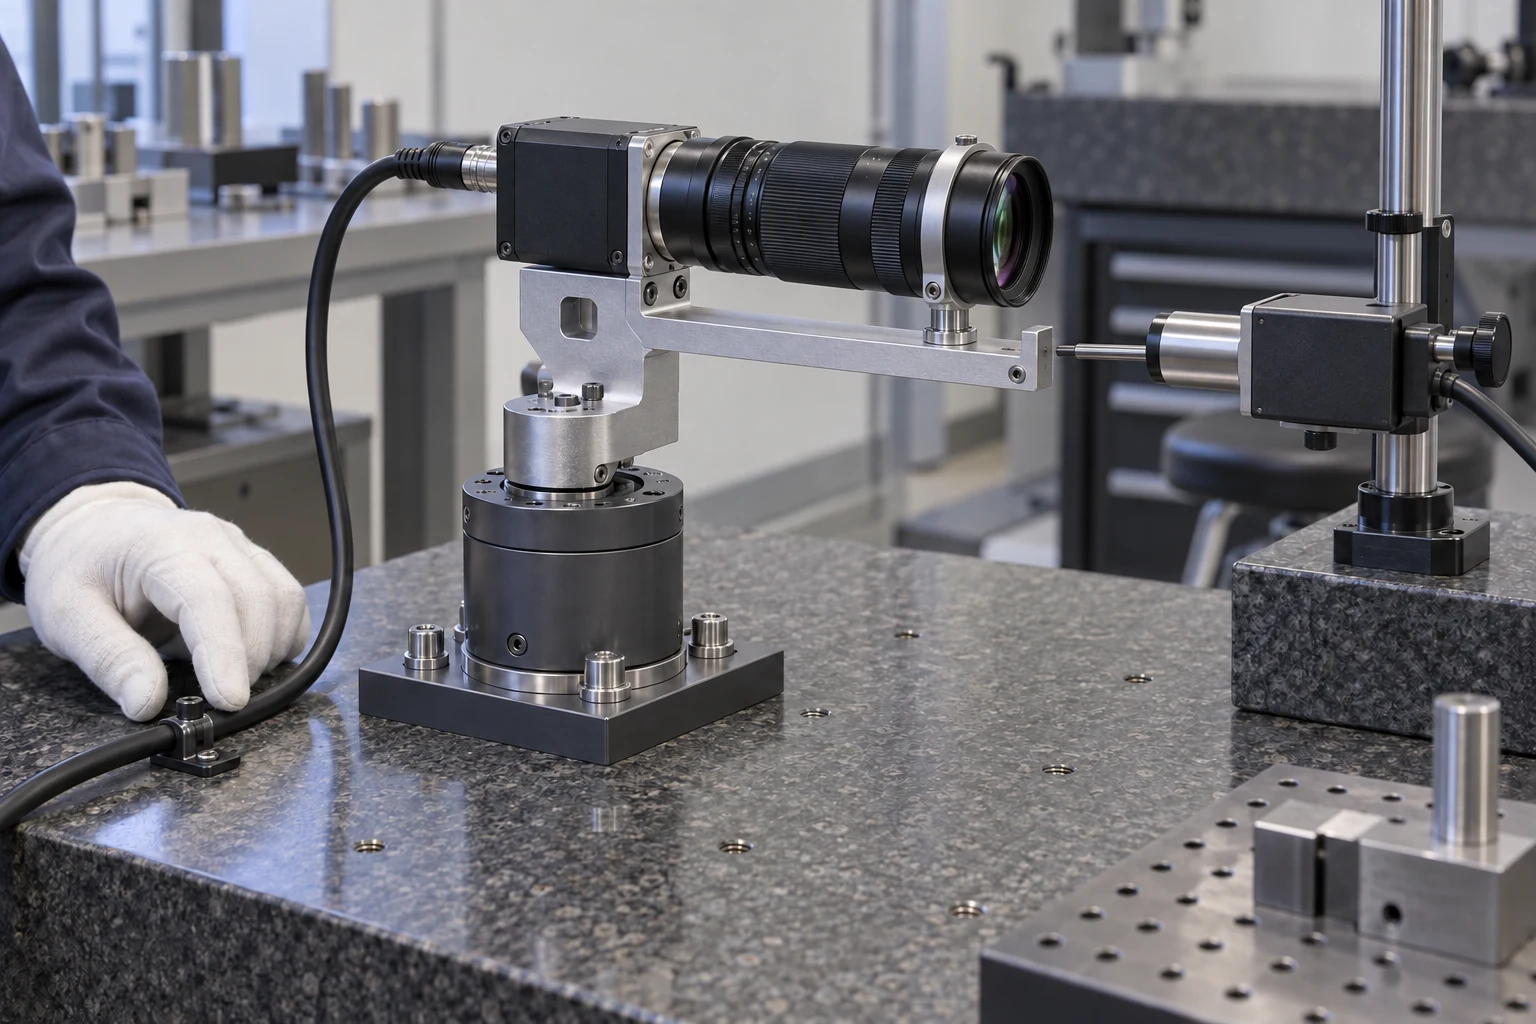
Which two parts does the encoder compare?
An encoder can give the correct joint angle while a stationary roof detail moves across the camera view. The fault may lie beyond the measured joint: the camera bracket bends, the lens support shifts, or the entire base tilts. A finer encoder would describe the same joint angle more finely.
Start with an ideal encoder directly measuring the output joint. Its scale and reader are attached to two different parts. It reports their relative rotation. It does not independently report either part’s orientation against the outside world, or the orientation of the optics farther along the structure.
For small angular changes in one plane, write the mechanical chain as:
Optical direction ≈ base angle + joint angle + bracket flex + optical alignment.
Each term has a different reference. Bracket flex means rotation relative to the joint output; optical alignment means the remaining angle between the bracket and the actual viewing direction. The encoder directly supplies only the joint term. Three-dimensional installations need the corresponding rotation geometry.
Engineers call the ability to infer internal motion from available measurements observability. If two possible mechanical states produce the same available readings, those readings cannot distinguish them. The formal definition concerns a whole measurement history, not one sample. MIT, Chapter 24.
Some flex couples back into joint motion and may be inferred with a validated model. But an unknown, slowly changing angle beyond the encoder cannot generally be recovered from that encoder alone. Adding another reader at the same mechanical boundary can improve the joint measurement while preserving this blind spot.
A correct relative angle does not establish the optical direction.
Follow the structure beyond the encoder
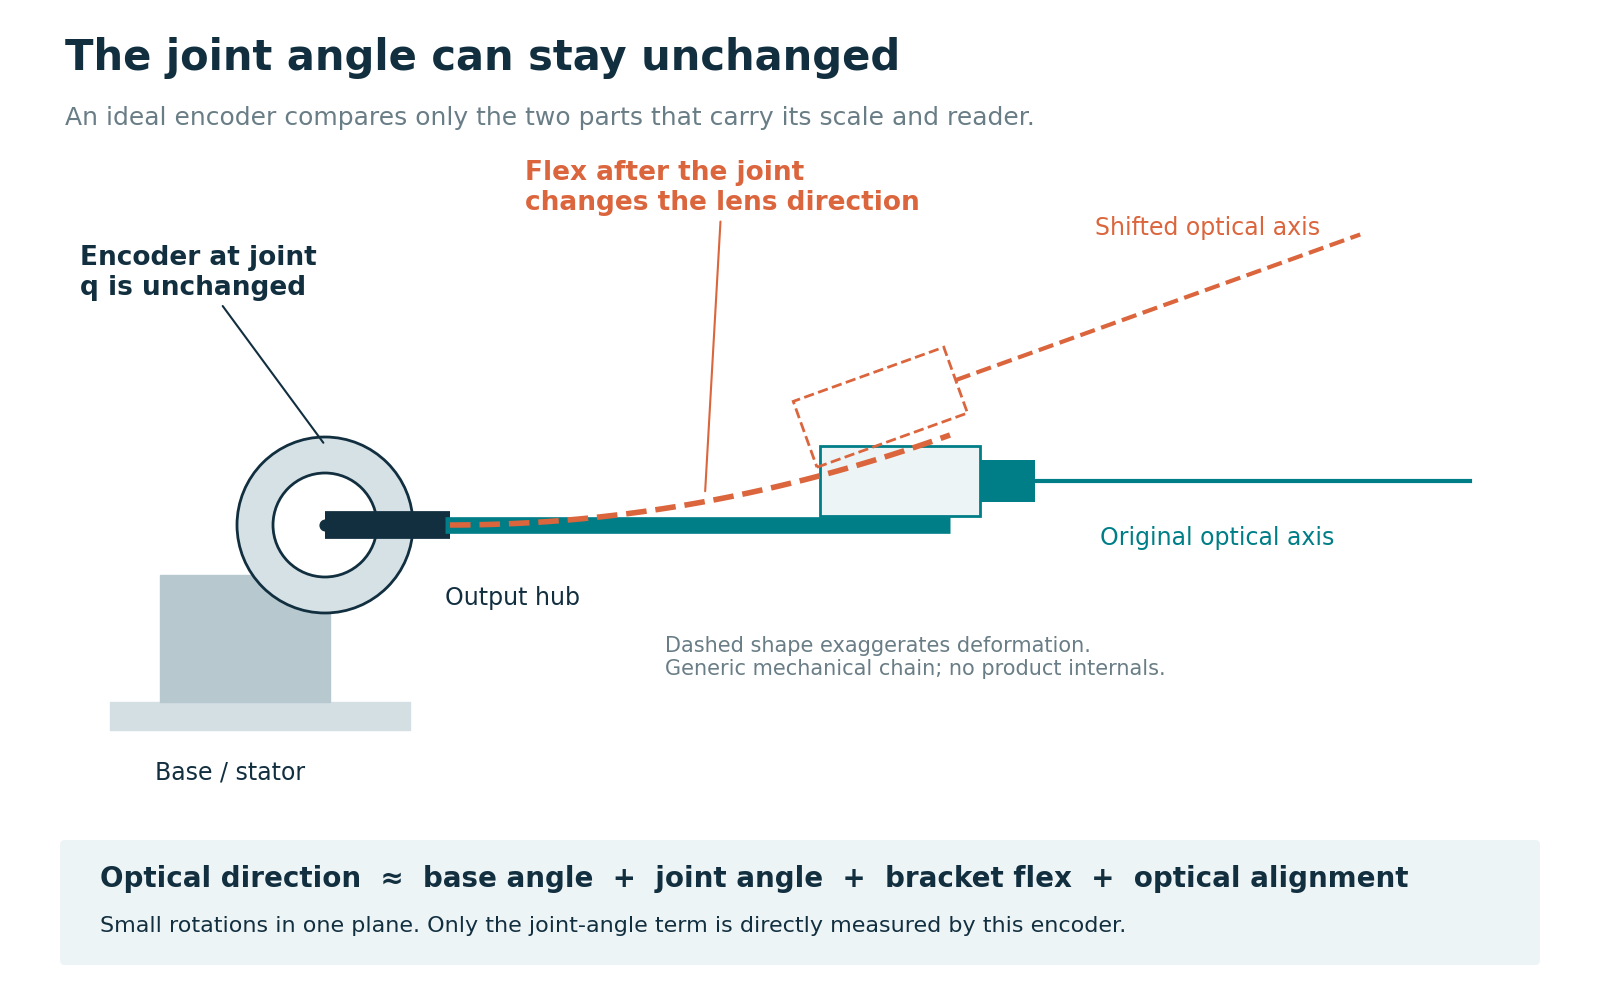
Mark the encoder boundary on the assembly drawing. Trace every part from there to the lens: output flange, fasteners, bracket, enclosure and optical supports. A cable force applied to the camera can bend this path without producing the relative joint rotation that the encoder measures.
Moving feedback closer to the payload can expose more of that path. An angular sensor on the camera bracket would respond to bracket motion. It would still miss a lens shifting relative to the bracket unless the measurement also includes the optical direction. Sensor location changes the question being answered; sensor count alone does not.
Boresight is the reference viewing direction established during alignment. Thermal expansion can change that direction when parts expand unequally or the temperature differs across the assembly. Uniform expansion of a symmetric, unconstrained structure need not create an angular change.
DTU and ESA researchers found temperature-related changes between camera heads sharing the Swarm optical bench. Their correction model included both temperatures and temperature differences between locations. A common bench did not make relative alignment constant. Swarm Optical Bench Stability.
For an outdoor camera, record temperatures at the relevant parts: the same ambient reading can accompany a sunlit bracket, a shaded base or an assembly warming after power-up. A correction fitted at settled temperatures may fail during transitions. Check heating and cooling histories before treating one temperature reading as a complete alignment correction.
Count a shared thermal cause once
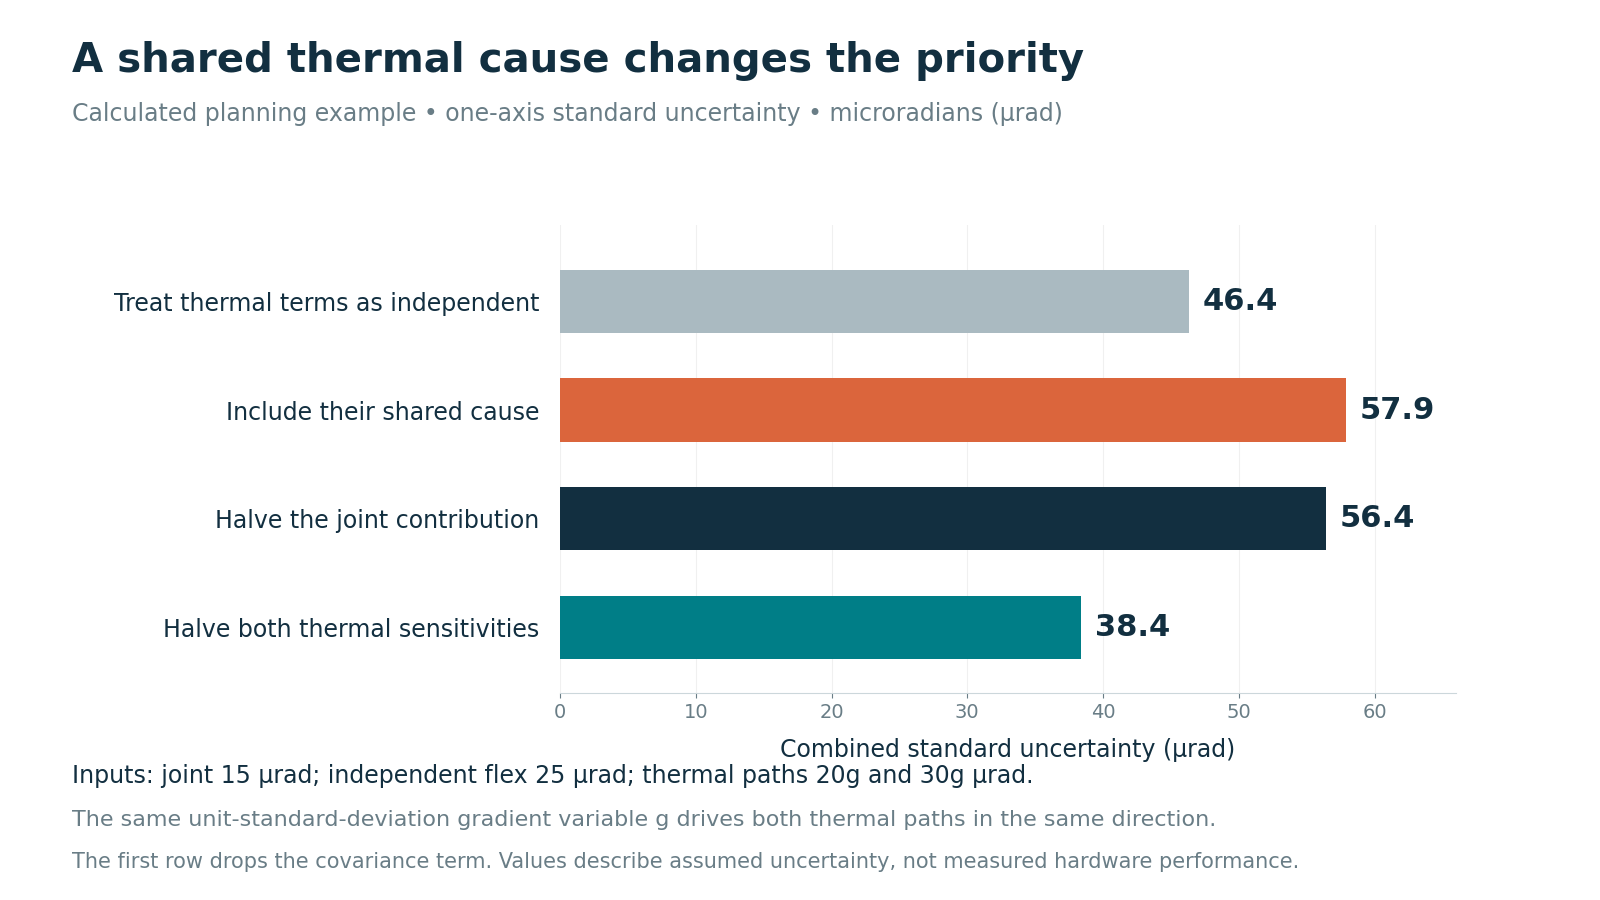
Consider a planning budget for one angular direction over a defined set of operating conditions. Known mean offsets have been corrected. Assume standard uncertainties of 15 microradians (µrad) from the remaining joint error and 25 µrad from other bracket flex. These two contributions are independent.
Now let one uncertain temperature gradient drive two further motions: 20g µrad at the bracket and 30g µrad inside the optical assembly. Here g is the gradient expressed relative to its standard uncertainty, with zero mean and standard deviation one. It is independent of the first two contributions. The thermal motions have the same sign and are perfectly correlated because both depend on g.
Their sum is 50g µrad, so u = √[15² + 25² + (20 + 30)²] = 57.9 µrad.
Treating all four terms as independent instead gives √(15² + 25² + 20² + 30²) = 46.4 µrad. That calculation drops the shared contribution. More generally, two thermal terms require the variance term 20² + 30² + 2ρ(20)(30), where ρ describes their correlation. This follows the NIST propagation law.
The decision changes with the budget. Halving the joint contribution to 7.5 µrad reduces the total only to 56.4 µrad. Halving both thermal sensitivities reduces it to 38.4 µrad. These are calculated comparisons, not hardware results.
Opposite thermal sensitivities can partially cancel: 20g − 30g = −10g, with standard uncertainty 10 µrad. Such cancellation needs evidence across the operating conditions. Do not also add an overall thermal-drift allowance that already contains these paths.
Standard uncertainty is a spread estimate, not a maximum excursion. Combine like quantities with consistent conditions; keep known offsets and worst-case limits separately identified. NIST uncertainty guidance.
Measure the view and protect the reference
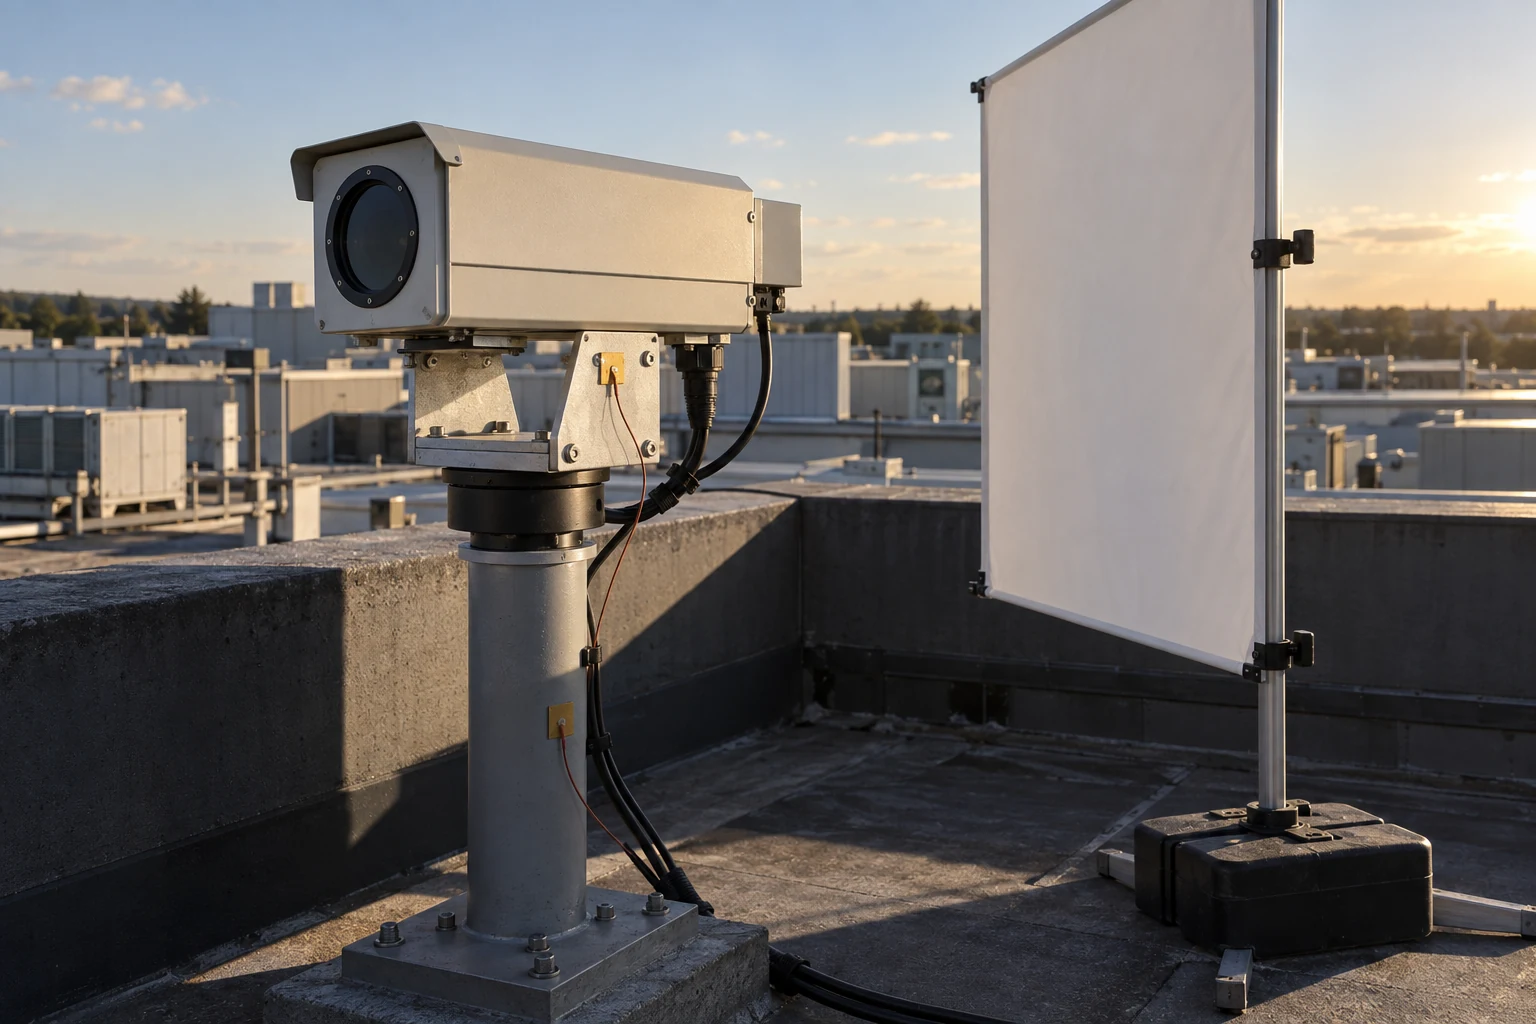
A useful test records three things together: joint angle, an optical reference and the conditions that could change the mounting path. Hold the commanded direction, focus and image processing constant. Observe a stable distant feature or a calibrated collimated target, which presents a fixed viewing direction without relying on a nearby object’s position.
Change one suspected cause within the assembly’s permitted conditions. Compare two supported cable routes, or shade the sunlit bracket while logging its temperature and that of the base. Allow the physical response to develop. If optical direction changes while the joint indication stays steady, the evidence points beyond that encoder’s measurement boundary. Repeat the comparison to separate a reproducible response from unrelated movement.
A mirror fixed to the camera housing is useful for detecting housing tilt. It does not by itself establish the viewing direction inside the camera. NASA’s OVIRS alignment work separately related external optical cubes to boresight and checked optical boresight at ambient and cryogenic conditions. The transferable lesson is to establish the relationship between the external reference and the optics. NASA metrology toolbox.
Also check what holds the reference. If the test target moves with the same bracket, relative agreement can hide their shared motion. Optical instruments have their own thermal and mounting errors: published autocollimator research shows that differential referencing suppresses several common effects while leaving others. Arp and colleagues.
For an Inventra S³ system, request evidence for the assembled camera, mount and sensor locations at the intended operating conditions. The decisive record is an optical result tied to an identified mechanical boundary, with reference uncertainty small enough to resolve the proposed improvement. That record tells the team whether to improve sensing, mounting stiffness or thermal alignment.
A test closes the budget only when its reference can reveal the missing motion.
Download the full article (PDF)
Related reading: The Better Stabilisation Ratio Can Give the Worse Result · Why a Steady Image Can Be the Blurrier One
Sources and further reading
- Lectures on Dynamic Systems and Control, Chapter 24: Observability
- Swarm Optical Bench Stability
- NIST TN 1297, Appendix A: Law of Propagation of Uncertainty
- Combining uncertainty components
- A Toolbox of Metrology-Based Techniques for Optical System Alignment
- A reference-beam autocollimator with nanoradian sensitivity from mHz to kHz and dynamic range of 10^7